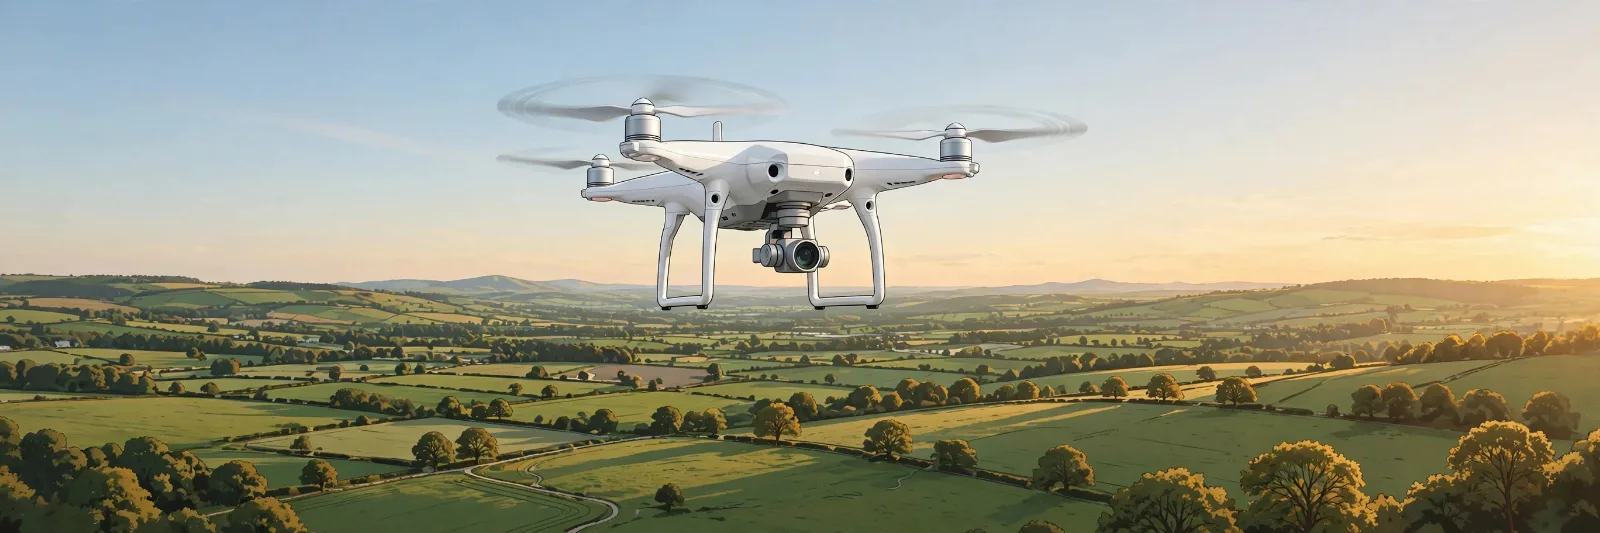
A drone hovering perfectly still in mid-air looks effortless. It is not. A quadcopter — the four-rotor drone most people own — has no natural stability at all. Left to itself with fixed motor speeds, it would tip over within a second or two. Every second of steady flight you have ever watched was actively computed, hundreds of times per second, by a tiny robot pilot on board.
Here is how that pilot works, how four spinning propellers steer in every direction without a tail rotor, and why your drone can find its way home all by itself.
The basic physics: push air down, go up
A drone flies on Newton's third law: for every action, there is an equal and opposite reaction. Each propeller spins fast, pushing air downward. The air pushes back upward on the propeller. Spin faster, push more air, get more lift. When the total upward lift from all four propellers exactly equals the drone's weight, it hovers. More lift than weight, and it climbs. Less, and it descends.
That sounds simple, but a helicopter solves the same problem very differently. A helicopter has one big main rotor and a tail rotor to stop the body spinning in the opposite direction. A quadcopter has no tail rotor, because it cancels that spinning force another way: two motors spin clockwise and two spin counter-clockwise, arranged in diagonal pairs. The twisting force from one pair cancels the other, so the body stays still. That arrangement is also the secret to steering.
How four rotors steer in every direction
The drone's brain — the flight controller — steers by changing each motor's speed individually. Every movement is just a different pattern of speeding some motors up and slowing others down:
- Up and down (throttle): all four motors speed up together to climb, or slow down together to descend. Hover is the exact balance point where total lift equals weight.
- Forward and backward (pitch): to fly forward, the rear motors speed up and the front motors slow down slightly. The drone tilts nose-down, so some of its lift now pushes it forward as well as up.
- Left and right (roll): the same idea sideways — motors on one side speed up, the other side slows down, and the drone tilts and slides in that direction.
- Turning in place (yaw): to rotate without tilting, the controller speeds up one diagonal pair and slows down the other. That unbalances the clockwise and counter-clockwise twisting forces, and the body rotates. No tilt is needed at all.
Between the flight controller and each motor sits an electronic speed controller (ESC), which converts the controller's command into exactly the right voltage and current to spin a brushless motor at the wanted speed. The whole loop — sense, decide, adjust — runs hundreds of times per second, far faster than any human could react.
The senses: how the drone knows what it is doing
A flight controller that only followed commands would crash in the first gust of wind. It needs to know, moment by moment, what the aircraft is actually doing. That job belongs to a set of sensors, most of them packed into one chip called the IMU (Inertial Measurement Unit):
- Gyroscopes measure rotation — how fast the drone is tilting or turning, in degrees per second. Modern drones use tiny MEMS gyroscopes etched into silicon, which detect rotation through the Coriolis effect on a vibrating structure. A gyroscope measures the rate of rotation, not the angle itself, so the controller must track changes over time.
- Accelerometers measure acceleration along three axes. Because gravity always pulls down at 1G, an accelerometer can tell which way is "down" and therefore how far the drone is tilted. That absolute reference stops small gyroscope errors from accumulating into a growing lean, a problem engineers call drift.
- Magnetometer (digital compass) measures Earth's magnetic field to give an absolute heading — which way the nose points — preventing drift in the turning direction too.
- Barometer measures air pressure to hold altitude. Air pressure falls predictably with height, so it gives a steady altitude reading even when satellite signals are weak.
- Satellite positioning (GPS and friends) gives position and velocity outdoors. Most consumer drones listen to several satellite systems at once — GPS, Galileo, GLONASS and BeiDou — which is why a drone can hold its position in the sky even in a breeze: it knows exactly where it should be and constantly corrects back to that spot. Our explainer on how GPS works covers the atomic-clock timing behind that trick.
- Vision and distance sensors look downward and around the drone. Downward cameras track patterns on the ground for stable hovering indoors where GPS does not reach, and obstacle sensors (cameras, infrared or ultrasonic) spot walls, trees and people to slow down or stop before a collision.
Fuse all of that together, and you get a machine that knows its tilt, heading, height, speed and position many times per second — and can correct any of them before you would even notice the error.
For how machines like this find their way, see how self-driving cars work.
Why drones do not fall out of the sky when something goes wrong
Modern consumer drones are designed around failure, not just success:
- Return to Home. If the control signal is lost, or the battery runs low, most drones automatically fly back to their takeoff point and land. They recorded that point from GPS at launch, and they retrace a safe route — climbing to a safe height first, then flying home.
- Low-battery landing. When the battery reaches a critical level, the drone will land where it is rather than fall. Battery life is the great limiter of drones: most consumer models fly for roughly 20–45 minutes, because lifting a battery, motors and camera into the air is energy-hungry work.
- Geofencing. Built-in maps of restricted airspace — around airports, for example — stop the drone from flying where it should not, or warn the pilot first.
- Redundant sensing. If GPS drops out, the drone falls back on its vision sensors and barometer to hold position.
What drones are actually used for
Camera drones get the attention, but the same four-rotor physics now does serious work:
- Filming and photography — smooth aerial shots that once needed a helicopter, now stabilised by a motorised gimbal that keeps the camera level even as the drone tilts.
- Farming — spraying crops precisely, mapping fields with multispectral cameras, and spotting stressed plants before a human eye would.
- Inspection — checking power lines, wind turbines, roofs and bridges without sending a person up a ladder or scaffolding.
- Search and rescue — thermal cameras on drones can find a lost walker at night faster than a ground team.
- Delivery trials — small parcels in rural areas, medical supplies between hospitals, and island deliveries where a road trip would take hours.
Drones versus helicopters versus planes
| Aircraft | How it lifts | How it steers | Best at |
|---|---|---|---|
| Quadcopter drone | Four rotors pushing air down | Varying individual motor speeds | Hovering, precise positioning |
| Helicopter | One main rotor + tail rotor | Tilting the rotor disc | Heavy lifting, long hover |
| Fixed-wing plane | Wings generating lift from forward speed | Ailerons, elevator, rudder | Distance, speed, efficiency |
Takeaway checklist
- A quadcopter flies by pushing air down with four propellers; lift equal to weight means hover, more lift means climb, less means descend.
- Two motors spin clockwise and two counter-clockwise in diagonal pairs, cancelling the twisting force so no tail rotor is needed.
- Steering is just motor-speed patterns: all together for height, one side faster for tilt, one diagonal pair faster for turning in place.
- The flight controller is a tiny robot pilot, adjusting motor speeds hundreds of times per second through electronic speed controllers.
- Its senses are the IMU (gyroscope + accelerometer), compass, barometer, satellite positioning and vision sensors — fused together for a constant picture of tilt, heading, height and position.
- Safety nets include Return to Home, low-battery landing and geofencing — but battery life (typically 20–45 minutes for consumer models) remains the main limit.
- Quadcopters trade range for precision: they are flying camera tripods, built to hover exactly where they are told.